 コンタクタ,サーキットブレーカー,センサー,エンコーダ,PLC,コンバータ
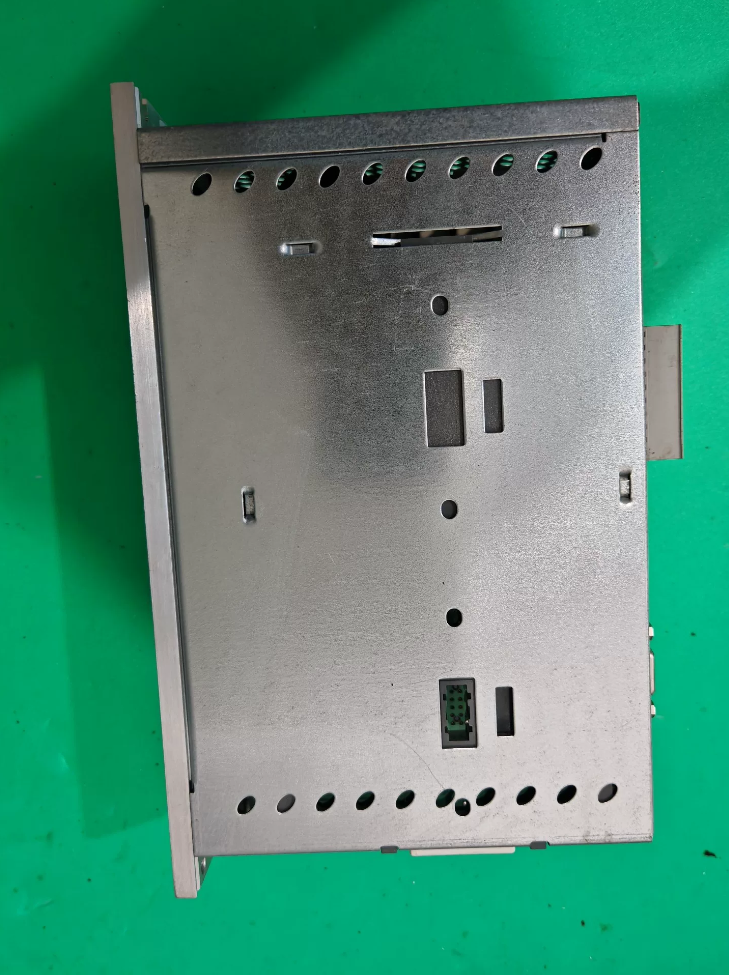
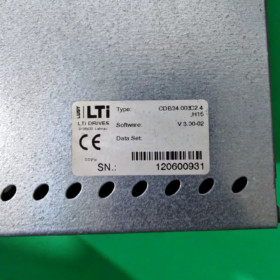
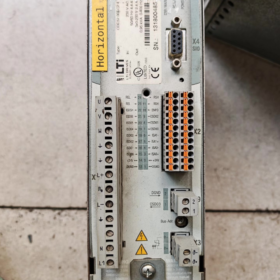
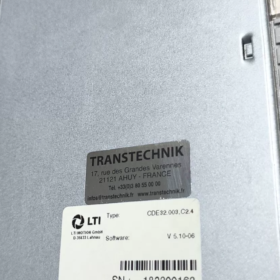
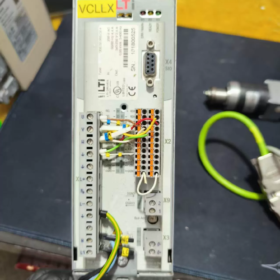
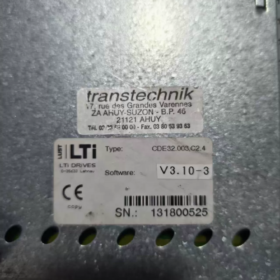
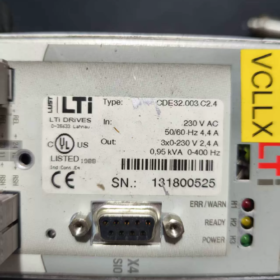
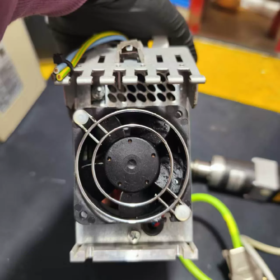
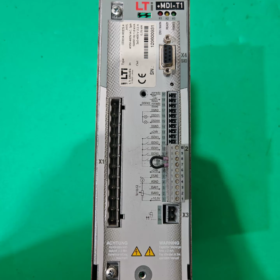
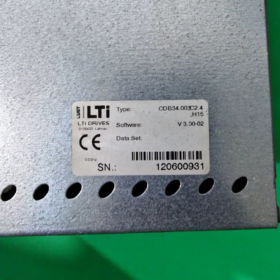
状態: EOLEndofLife. LUST was acquired by KEBA; OEM supply discontinued. 使用のみ / secondhand / refurbished units available on market.
- モデルコードのデコード
`CDE32.003.C2.4`
| セグメント | 意味 |
| CDE | シリーズ: Pos‑Servo CDE3000 series, 位置決め servo drive; サポート位置 / スピード / トルク制御モード |
| 32 | 電圧クラス: 3×230 V AC; 34 stands for 400 V class |
| 3 | Rated output‑current code: 3 A continuous, 6 A peak |
| C | Hardware revision C |
| 2 | Encoder interface: EnDat 2.2 |
| 4 | Firmware version V2.4; suffix .PC1 = Profibus‑DP option board (not included in base unit CDE32.003.C2.4) |
Order reference: `1021.0003.x` (base order code for CDE32.003 series)
- 主要な電気仕様
| アイテム | パラメータ |
| 主電源 | 3‑phase 208‑230 V AC, 50‑60Hz |
| 制御電源 | 24 V DC external supply |
| Continuous output current | 3 A rms |
| Peak output current | 6 あ (duration limited by overload curve) |
| Compatible motor power | 0.25‑0.75 kW, 230 V LUST synchronous servo motors |
| Control modes | 位置 (on‑board positioning), スピードループ, torque loop |
| エンコーダ | EnDat 2.2 (Hardware C2.4); TTL incremental optional on other hardware variants |
| I/O | デジタル入力 / 出力, analog ±10 V setpoint; X2 control terminal block |
| Motor brake output | Terminal X9, 24 V motor brake drive with cable‑break monitoring |
環境条件
動作温度: 0 ~ +45 °C (cabinet installation with forced ventilation; derating above 40 °C)
ストレージ / 輸送温度: −25 ~ +70 °C
湿度: 590 %RH, no condensation permitted
取り付け: DINrail mounting inside cabinet; IP20
機械的寸法 (CDE32 small housing)
Width 55 mm × Height 215 mm × Depth 150 mm; prefitted DINrail clips.
- Interface Overview
- X1: 3phase main power input L1/L2/L3, DCbus brakeresistor terminals
- X2: Control I/O (デジタルI/O, analog setpoint, enable, faultrelay output)
- X6: Motor power output U/V/W, PE protective earth
- X7: EnDat encoder port
- X9: 24 V motorbrake output; requires external 24 V supply, cablebreak detection included
- KP200: Handheld keypad interface for parameter access and fault reading
Commissioning software: DriveManager (legacy LUST tool; native support for Windows XP / 7; compatibility mode required for Win10).
- Quick FaultCode Reference (CDE3000 series)
| 画面 | 障害の説明 | Typical Root Causes |
| E‑CPU | CPU / firmware hardware fault | Main‑board damage, parameter corruption, RAM failure |
| E‑OC | 過電流 | Motor short‑circuit, earth‑fault, power‑stage failure, motor insulation breakdown |
| オフ | DC‑bus undervoltage | 3‑phase input phase‑loss, insufficient main‑supply voltage |
| E‑OTI | Drive over‑temperature | 放熱が悪い, fan failure, excessive ambient temperature |
| E‑OTM | Motor over‑temperature | Motor thermistor open‑circuit, モーターの過負荷 |
| E‑PLS | エンコーダの故障 | EnDat communication error, damaged cable, encoder hardware failure |
| E‑CAN | CAN bus fault | Missing 120 Ω termination resistor, bus short‑circuit |
H1 redLED blink code: number of blinks indicates fault group; full fault information readable via KP200 keypad.
- 交換オプション (重要: No pintopin dropin compatible replacement; hardware, wiring and software must be reworked completely)
結論: There is no plugandplay alternative. Two strategies: equipment retention via repair; or fullsystem upgrade.
Strategy 1: Repairbased retention of existing machine
Source used / secondhand CDE32.003.C2.4. リスク: limited availability, component ageing. Powerboard inspection and capacitor refurbishment recommended.
Verify firmware version and encoder type (EnDat 2.2) for matching with existing motor.
Strategy 2: Full upgrade (KEBA successor & 3rdparty servos)
- KEBA KeDrive D3 series (technical inheritance from LUST): Requires new electrical drawings, encoder reconfiguration. DriveManager project files cannot be imported directly.
- 3rdparty candidates: Schneider Lexium 28, B&R ACOPOSmicro, Siemens S210.
Critical note: Original motor uses EnDat 2.2 encoder. New drive must support EnDat interface to reuse existing motor.
Selection Pitfall Warnings
- ❌ Never replace CDE32 (230 Vクラス) with CDE34 (400 Vクラス); voltage mismatch will destroy motor.
- ❌ Suffix C2.4 denotes EnDat hardware; cannot directly substitute C1.x (TTL incremental encoder) variants; encoder hardware is incompatible.
- Legacy DriveManager project files cannot be imported into KEBA KeDrive; full retuning mandatory.
- TypicalApplication Fields
繊維機械, 印刷機, 包装装置
Auxiliary axes for machinetools, 位置決めテーブル
Woodworking machinery; mostly found on legacy imported equipment.
- 標準パッケージ内容
Servo drive CDE32.003.C2.4 ×1
Preinstalled DINrail mounting clips
Items NOT included, must be ordered separately: KP200 keypad, ProfibusDP PC1 option board, encoder cables, power cables, external braking resistor.
Compatible Original LUST Synchronous ServoMotors
Drive hardware: C2 = EnDat 2.2 absolute encoder interface; drive continuous 3 A, peak 6 A; 3×230 V AC supply.
Hard constraints: Motor must be 230 V winding synchronous servo with EnDat 2.2 (singleturn / multiturn). Motor continuous current ≤ 3 A, peak ≤ 6 A. パワーレンジ: 0.250.75 kW. 400 Vwinding motors are not supported. TTL incrementalencoder motors (for C1hardware drives) cannot operate directly with this unit.
Original motor families LS, LSM, LSML (欲望 / LTi) are all EOL. 使用のみ / refurbished units available.
- OEM Compatible Motor List (EnDat 2.2, 230 V)
| モーター型式 | 定格電力 | 定格トルク | 定格速度 | 定格電流 | 備考 |
| LS‑07‑030‑2N‑000 | 250 W | 0.8 Nm | 3000 rpm | 1.4 あ | Small flange, ブレーキがありません, EnDat 2.2 |
| LS‑07‑050‑2N‑000 | 400 W | 1.27 Nm | 3000 rpm | 2.1 あ | No‑brake; brake variant suffix‑B000 |
| LS‑08‑075‑2N‑000 | 750 W | 2.39 Nm | 3000 rpm | 2.8 あ | Maximum compatible power. Continuous operation at full load not permitted; derating required. |
| LSML‑07‑030‑4N‑000 | 250 W | 0.8 Nm | 4500 rpm | 1.5 あ | High‑speed low‑inertia; for high‑speed axes in textile / 梱包 |
| LSML‑07‑050‑4N‑000 | 400 W | 1.27 Nm | 4500 rpm | 2.2 あ | High‑speed no‑brake;‑B4N = 24 V holding brake |
| LSMM‑08‑075‑2N‑000 | 750 W | 2.4 Nm | 3000 rpm | 2.9 あ | 中慣性, 80 mm flange; auxiliary machine‑tool axes |
Modelcode breakdown example `LS070502NB000`
- `LS`: standardinertia synchronous servo; `LSML`: lowinertia highspeed; `LSMM`: mediuminertia
- `07 / 08`: flange code (07 = 70 mm; 08 = 80 mm)
- `030 / 050 / 075`: power ×10 W (075 = 750 W)
- `2` = 3000 rpm; `4` = 4500 rpm
- `N` = EnDat 2.2 encoder; `I` = TTL incremental encoder (NOT for this drive)
- `B` = integrated 24 V holding brake; noB = brakeless.
- Electrical Boundary Conditions (Selection Hard Rules)
- Current limit: Motor continuous RMS current ≤ 3 A; motor peak current ≤ 6 A. 750 W is upper power limit; avoid continuous fullload operation, apply derating.
- Encoder mandatory match: X7 hardware is EnDat 2.2. Motor encoder suffix must be2N /4N. Isuffix TTL incremental motors plugged into X7 trigger EPLS encoder failure.
- Winding voltage: Must be 230 V winding. 400 Vwinding motors strictly forbidden on CDE32; excitation cannot function correctly.
- Brake drive: Motorintegrated 24 V holding brake connects to X9. X9 requires independent external 24 V supply; drive does not source brake power. Cablebreak monitoring active.
- Motor temperature sensor: Onboard PTC thermistor may be connected for driveside monitoring, triggers EOTM motorovertemperature.
- 3rdParty Motor Compatibility Requirements
CDE32.003.C2.4 can drive 3rdparty permanentmagnet synchronous motors only if all conditions are satisfied:
- Motor winding 3×230 V AC; continuous phase current ≤ 3 A.
- フィードバック: Heidenhain EnDat 2.2, DSub15 pinout matching LUST cable specification.
- All motor parameters must be manually entered in DriveManager: stator resistance, d/qaxis inductance, polepair count, 継続的な / peak current, backEMF Ke. No preloaded motor database; no autorecognition.
⚠️ Risk: Incorrect tuning of 3rdparty motors leads to EOC overcurrent, axis oscillation or poor positioning accuracy. Prefer original LS / LSML series motors.
- Common MismatchRelated Faults
| 故障コード | 現象 | 根本的な原因 |
| E‑PLS | Encoder alarm | Motor fitted with TTL‑I instead of EnDat‑N; cable damage; pin‑out mismatch |
| E‑OC on enable | Immediate over‑current upon enable | 400 V‑winding motor connected; motor winding short‑circuit; wrong pole‑pair / inductance parameters |
| E‑OTM motor over‑temp alarm | Motor physically cool | PTC thermistor wiring missing; motor mechanical overload |
| トルク不足 / low maximum speed | Motor rated‑current exceeds drive 3 A rating; wrong back‑EMF setting |
- MotorDrive System Upgrade Paths (when original motor fails)
- Repair route: Source used LSxxxxx2N /4N motor. Verify EnDat 2.2 encoder health, check ratedcurrent, retune via DriveManager.
- Fullsystem replacement route: KEBA KeDrive D3 drive plus KEBA synchronousmotor; or 3rdparty servo. Match original mechanical flange and shaft dimensions.
注記: Existing DriveManager motor parameters cannot be imported into new platform; full retuning is required.
- Associated Cabling
- Motor power cable: LUSTspec power cable U/V/W/PE including PTC temperature feedback conductors.
- Encoder cable: Doubleshielded dedicated EnDat 2.2 DSub15 cable. Do NOT reuse TTL incremental encoder cables.
- Brake conductors integrated within power cable, routed to X9.
LUST CDE3000 (CDE32.003.C2.4) Complete FaultCode Table
注意事項:
- H1 redLED blink count = main fault group number. Detailed subfault codes readable via KP200 or DriveManager.
- Fault reset: powercycle; or pressandhold KP200 STOP key ≥ 3 s; or software faultacknowledge.
- Many faults carry subcodes stored in parameter `ERPAR`, read in DriveManager for precise diagnosis.
- Valid for CDE32 / CDE34 families. For CDE32.003.C2.4 (EnDat 2.2) pay special attention to EPLS.
- Main Fault Table (H1 blink count / KP200 display)
| Blinks | 画面 | Fault Name | 説明 | 根本的な原因 & 救済策 |
| 1 | E‑CPU | CPU / Processor Fault | Controller hardware / ファームウェアの異常 | ① 電源を入れ直します リセット. ② 再発はメインボードの故障を示します; 制御基板を交換する. |
| 2 | E-OFF | DC バスの不足電圧トリップ | DC バス電圧がしきい値を下回る | ① 三相入力欠相 / 供給電圧が低い. ② 主回路ヒューズが切れている. パワーダウン中の短い通常の現象. |
| 3 | E‑OC | 過電流トリップ | 出力電流制限違反; ハードウェアまたはソフトウェアの保護 | サブコード: 19ソフトウェア過電流; 34fast Ixt 過電流; 35パワーオンセルフテスト短絡; 41ハードウェアパワーステージ過電流. |
| U/V‑W 短絡を確認してください, モーター地絡, パワーモジュールの損傷, 間違ったモーターパラメータ, cable damage. | ||||
| 4 | E-OV | DC バス過電圧トリップ | 回生エネルギーによる DC バス過電圧 | ① 電源過電圧. ② 減速勾配が急すぎる. ③行方不明 / 破損した制動抵抗器. ブレーキ抵抗器を取り付ける; 減速時間を延長する. |
| 5 | E‑OLM | モーター I²t 過負荷保護 | モーターの熱モデル過負荷タイムアウト | 機械的な妨害; 過負荷; 高い加速率. モーターパラメータを確認する; 機械的負荷を軽減する; メカニックを検査する. |
| 6 | エオリ | ドライブ I²t 過負荷保護 | パワーステージの熱過負荷タイムアウト | 定格容量を超える連続運転. ディレーティングを適用する; 電力サイジングを検証する; キャビネットの冷却を改善する. |
| 7 | E‑OTM | モーター過熱障害 | PTCサーミスタトリガー | ①壊れた / PTC 回路の配線が間違っている. ②純正モーターの熱過負荷. 実際のモーター温度と X2 PTC 配線を確認してください. |
| 8 | E‑OTI | ドライブの過熱障害 | ヒートシンク / 内部 PCB の過熱. サブコード31ヒートシンクの過熱; 32 キャビネット内部の過熱. | Poor cabinet ventilation; fan fault; ambient > 45 °C. Clear airflow derating; reduce enclosure temperature. |
| 9 | E‑PLS | エンコーダ / Feedback Checksum Fault | Invalid feedback signal, encoder communication failure, position‑check error | High‑frequency alarm for C2.4 EnDat 2.2 variant. |
| Check X7 encoder‑cable damage, poor shield‑grounding, bent D‑Sub‑15 pins, encoder hardware failure. Never fit TTL incremental cables to EnDat port. | ||||
| 10 | E‑PAR | Parameter Error | Parameter out‑of‑bounds, initialization failure; faulty‑parameter‑ID stored in ERPAR | Corrupted parameter download; out‑of‑range settings. Restore factory defaults; reload valid motor‑parameter‑set. |
| 11 | E‑EEP | EEPROM Storage Fault | Non‑volatile‑memory read‑write error | Power‑cycle reset. Repetitive fault indicates EEPROM chip hardware damage on main‑board. |
| 12 | E‑CAN | CAN‑バス障害 | CANopen通信障害; サブコードはバスオフをカバーします, ハートビートエラー, PDO 例外 | バス端に 120Ω 終端抵抗がありません; bus short‑circuit; 競合するノード ID; ボーレートの不一致; 欠陥のあるケーブル. |
| 13 | エポス | 位置決め異常 | オンボード位置コントローラの故障; ターゲット位置のオーバーフロー; 次のエラーしきい値を超えました | 機械的焼き付き; サーボゲインの調整が不十分; フォローエラーしきい値の設定が低すぎます. 機構と位置/速度ループパラメータを検査する. |
| 14 | 電子PLC | オンボードシーケンサーの障害 | ユーザーマクロ実行時エラー; スタックオーバーフロー, ゼロ除算, 構文エラー | カスタム PLC マクロ コードを検査する. ユーザープログラムのクリア; 工場出荷時のマクロセットを復元する. DriveManager で障害線番号のサブコードを読み取る. |
| 15 | E‑BR | ブレーキユニットの故障 | 内部ブレーキチョッパーの故障; ブレーキ抵抗器の短絡 / 開回路 | ブレーキ抵抗器の抵抗値が間違っています; 抵抗の断線; ブレーキ・パワー・ボードの損傷. 抵抗の仕様を確認する. |
| 16 | 外部 | 外部故障入力 | X2 端子の外部障害信号 (パラメータ524で設定されたロジック) | 外部機器によってアサートされた障害信号. 外部フォールトループ配線とパラメータ構成を検査する. |
- 選択された ERPAR サブコード定義
EOC (過電流) サブコード
19: ソフトウェア過電流保護
34: 高速 Ixt オーバーロード (低周波短絡状態)
35: 電源投入時セルフテスト中に短絡が検出されました
41: ハードウェアパワーステージの過電流
EOTI サブコード
31: ヒートシンクの過熱
32: ドライブ内部チャンバーの過熱
ECAN 選択されたサブコード
31: バスオフ状態
39: ハートビート監視の失敗
40: 無効なCANノードIDです
42: PDO同期監視エラー
EPAR 選択されたサブコード
5: パラメータダウンロードのオーバーフロー
6: Parametertable initialization failure
7: Parametersave failure
8: Parameterread failure
47: Motorprotectionparameter initialization error
100123: Controlmodule initialization failures (currentloop, speedloop, positionloop, encoderinterface)
- 警告 (WARN: no drive trip; statusbit only)
WARNOLM: Motor overload prewarning (pretrip threshold)
WARNOLI: Drive overload prewarning
WARNOTM: Motor temperature prewarning
WARNOTI: Drive temperature prewarning
Warnings do not disable powerstage; read status bits in DriveManager / PLC for proactive load / coolingcondition inspection.
- HighFrequency Troubleshooting for CDE32.003.C2.4 (EnDat 2.2)
- EPLS (mostcommon fault)
Symptoms: Alarm at poweron OR random runtime trips.
原因: Damaged X7 EnDat cable; bent DSub15 pins; TTLencoder motor connected to C2 hardware; encoder hardware failure; poor shieldearthing.
禁止: Never insert TTL incrementalencoder cables into EnDat port.
- EOC on enable
Verify motor winding is 230 V class (400 V windings forbidden). Check motorparameter entry (polepair count, stator d/q inductance).
- Frequent EOFF undervoltage trips
CDE32 requires full 3phase 230 V supply. Confirm L1L2L3 are all connected; no phaseloss.
- EOTM alarm while motor is physically cool
Check X2 PTC thermistor wiring. If motor has no PTC sensor, disable PTC monitoring in parameters.
- General FaultHandling Workflow
- Record panel fault code. If possible connect DriveManager and capture faultlog plus ERPAR subcode.
- Poweroff; disconnect motor powercable and encodercable to isolate whether fault originates from drive, cable or motor.
- Measure motor insulation resistance, PTC resistance, and brakeresistor ohmic value.
- Restore factory parameters; reload valid OEM motorparameterset; retune currentloop and speedloop.
- Hardwarerelated faults (ECPU, hardwaresubcode EOC): repair or replace drive unit.
NH42-63-318x560.png "CHINT PC型自動切替スイッチ (ATS)NH42-63/4SZ")