 Контактор,автоматический выключатель,датчик,Кодер,ПЛК,Конвертер
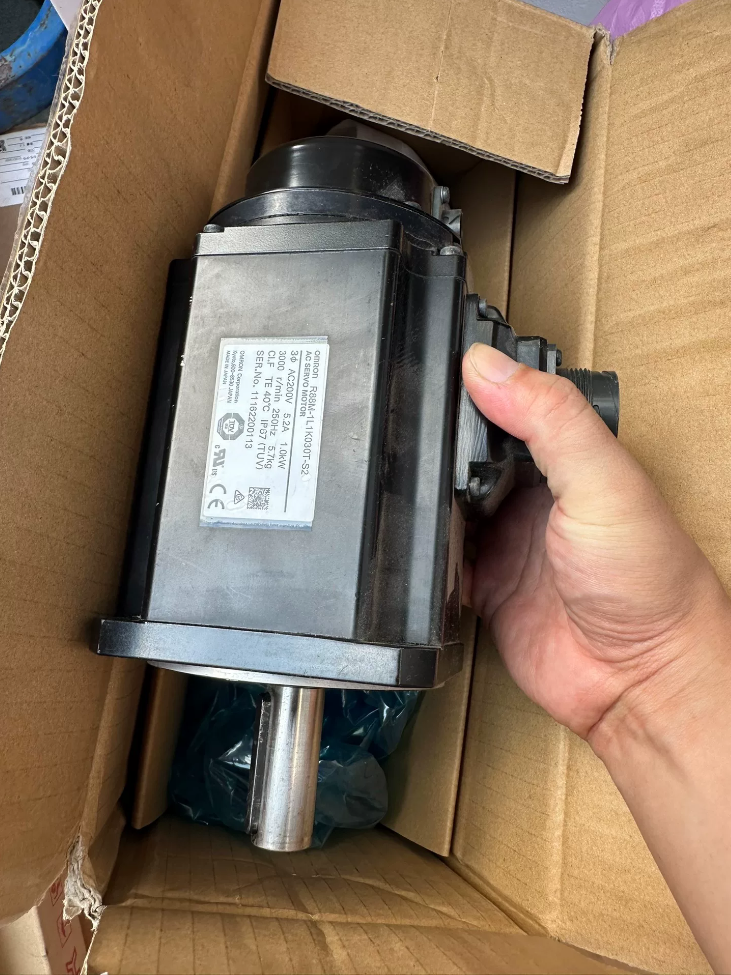
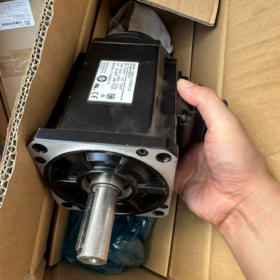
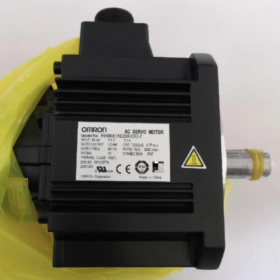
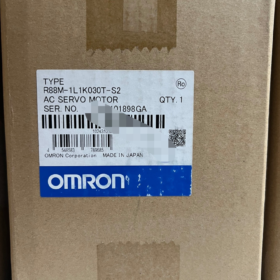
Ряд: 1S Series Low-Inertia Серводвигатель переменного тока, compatible with EtherCAT bus servo drives, battery-free absolute encoder model
✅ Model Decoding
R88M-1L1K030T-S2
Р88М: ОМРОН servo motor prefix
1: 1Серия S
л: Low inertia motor
1К0: Rated power 1kW
30: Rated speed 3000 об/мин
Т: 23-bit battery-free absolute encoder (АБС)
С2: With keyway + tapped hole on shaft end; нет тормоза, no oil seal
📋 Main Electrical Specifications
| Элемент | Параметр |
| Номинальная мощность | 1000 Вт (1кВт) |
| Номинальная скорость | 3000 об/мин |
| Максимальная скорость | 5000 об/мин |
| Номинальный крутящий момент | 3.18 Н·м |
| Instantaneous Peak Torque | 9.55 Н·м (3× overload) |
| Номинальный ток | 5.2 А (rms) |
| Пиковый ток | 16.9 А (rms) |
| Кодер | 23-bit battery-free absolute encoder |
| Источник питания | Однофазный переменный ток 230 В |
| Инерция ротора | 4.2 ×10⁻⁴ кг·м² (без тормоза) |
| Allowable Load Inertia | Макс. 42 ×10⁻⁴ кг·м² |
📐 Mechanical Specifications
Фланец: 100mm square flange
Диаметр вала: φ19mm, with flat key + M5 tapped hole at shaft end
Масса: 5.7 кг
Тормоз: No electromagnetic brake (brake model: R88M-1L1K030T-BS2)
Oil Seal: No oil seal (O suffix option for oil seal)
🔌 Matching Drive
Must be paired with OMRON 1S series EtherCAT servo drive:
R88D-1SN10F-ECT (однофазный 230В, 1kW EtherCAT drive)
🧩 Typical Applications
EtherCAT bus equipment: automated assembly lines, ЧПУ, laser equipment, handling manipulators, high-speed positioning platforms, упаковочное оборудование. Low inertia design suitable for frequent start-stop and fast response motion control.
⚠️ Key Features
- Battery-free absolute encoder: Position retention at power-off, no battery maintenance, eliminates risk of origin loss caused by battery failure
- Шина EtherCAT, high-speed synchronization for multi-axis coordination
- 3× short-time overload capability to handle impact loads
- Low inertia rotor for excellent dynamic response
📌 Related Model Selection Reference
R88M-1L1K030H-S2: 1кВт, 3000об/мин, incremental encoder, with keyway
R88M-1L1K030T-BS2: 1кВт, 3000об/мин, абсолютный энкодер, with 24V brake
R88M-1L1K030T-OS2: 1кВт, 3000об/мин, абсолютный энкодер, with oil seal + шпоночный паз
📎 Matching Cable Part Numbers
Power Cable: R88A-CA1G□□□
Encoder Cable: R88A-CR1G□□□
Troubleshooting Checklist for OMRON 1S Servo R88M-1L1K030T-S2 + R88D-1SN10F-ECT
Предварительное условие: Motor equipped with 23-bit battery-free absolute encoder, нет тормоза; EtherCAT bus drive with STO safety terminals. ⚠️ Insulation test (megger) must be performed with motor disconnected from drive. Never apply high voltage/megger test while drive is connected; power module will be burned out directly.
- Pre-power-on Basic Inspection (Power OFF)
- Mechanical Check
Manually turn motor shaft: smooth rotation without jamming or metal friction noise; seizure = bearing damage / mechanical load stuck
Tighten flange and coupling screws; excessive misalignment causes vibration and overload
Verify load inertia: maximum allowable load inertia 42×10⁻⁴ kg·m², excess will lead to oscillation and overload alarms
- Кабели & Connectors
Power cable U/V/W/PE: check for outer sheath damage, loose or oxidized pins; measure phase resistance with multimeter, three-phase resistance should be balanced; confirm no short circuit between U/V/W and ground
Encoder cable: secure connectors, shield grounded at drive side only; do not bundle encoder cables in parallel with power cables (interference source)
EtherCAT cable: intact RJ45 connector, verify OP state; follow IN/OUT sequence for multi-axis systems
- Силовая цепь
Single-phase AC230V input, voltage range 180~264VAC; check circuit breaker and contactor contacts
Reliable PE grounding, common ground for drive and motor; poor grounding easily triggers encoder communication alarms
- Power ON, No Alarm, but Servo Cannot Enable (SON cannot turn ON)
- Check STO safety terminals: STO1/STO2 must be short-circuited. Disconnected STO prevents servo ON and triggers safety-related alarms
- EtherCAT Status: confirm bus enters OP state; INIT/PREOP means communication failure, controller cannot send enable commands
- Drive Input Terminals: check if ESTP emergency stop is triggered; limit switch logic
- Controller Program: MC_Power instruction, axis enable logic, axis configuration (matched motor model)
- Parameter Verification: motor code, encoder type must be set to Battery-free ABS
- Main Drive Alarm Code Troubleshooting
| Alarm Code | Alarm Name | Точки устранения неполадок |
| 1 | Перегрузка по току | U/V/W short circuit or earth fault; motor coil insulation damage; drive power module failure; wrong phase sequence; noise false alarm |
| 12 | Motor Overheat | Постоянная перегрузка; высокая температура окружающей среды; poor motor heat dissipation; broken motor temperature sensor |
| 13 | Пониженное напряжение главной цепи | Low AC230V input; voltage drop at power-up; недостаточная мощность мощности; blown main circuit fuse |
| 14.00/14.01/14.02 | Regeneration Fault / Regeneration Overload | Excessively fast deceleration; broken/wrong resistance value of external regenerative resistor; excessive load inertia; insufficient power supply capacity |
| 16 | Перегрев привода | Blocked drive fan; poor cabinet heat dissipation; long-time overload |
| 21 | Encoder Communication Disconnect | Loose encoder plug, сломанный кабель; abnormal encoder power supply; damaged pin; cable interference |
| 21.01 | Encoder Communication Error | Poor shield grounding, помехи в силовом кабеле; internal encoder fault; overlong cable |
| 24 | Position Deviation Excess | Механическое заклинивание, тяжелая нагрузка; low gain; too short acceleration/deceleration time; slipping coupling; abnormal command pulse |
| 24.01 | Speed Deviation Excess | Mechanical binding; torque saturation; mismatched gain |
| 26 | Overspeed | Incorrect electronic gear ratio; abnormal command; load inertia pulling motor runaway; high gain induced oscillation |
| 27.01 | Absolute Value Clear (Battery-free ABS) | Home origin setup for first use; shaft rotated by external force while powered off; internal encoder fault, home reset required |
| 87 | External Emergency Stop ESTP | Emergency stop circuit open, check E-stop button and wiring |
- Abnormal Motor Operation (No Alarm or Minor Warning)
4.1 Motor Shaking, Аномальный шум, Вибрация
Механический: coupling misalignment, механический люфт, load resonance
Контроль: excessive gain; inertia identification not completed; improper acceleration/deceleration setting
Электрический: encoder interference; unbalanced three-phase current; poor contact of power cable
4.2 Severe Motor Heating
Continuous load exceeds rated torque; frequent start-stop; высокая температура окружающей среды
Current Monitoring: monitor motor current via drive; continuous current near rated 5.2A indicates heavy load
4.3 Poor Positioning Accuracy, Origin Loss (Battery-free ABS model)
R88M-1L1K030T-S2: Battery-free absolute encoder. Position is retained if shaft stays stationary at power-off. Origin will be lost and 27.01 alarm triggered if shaft is rotated by external force during power-off.
Check encoder cable shield; loose connector caused by vibration
Mechanical backlash, slipping coupling
If shaft is rotated externally after every power cut → home return required every power-up
- EtherCAT Communication Faults
- Bus stuck at PREOP: поврежденный кабель, wrong wiring sequence, incorrect slave ID; mismatched drive firmware version
- Intermittent bus disconnection during operation: poor cable shielding; помехи в силовом кабеле; power noise; loose RJ45 connector
- Occasional PDO frame loss: reduce bus cycle time; extend communication watchdog time; optimize grounding
- Isolation Test Method (Quickly Locate Fault: Мотор / Кабель / Водить машину)
- Separate Motor and Drive Test
Disconnect power cable and encoder cable; power on drive alone. If alarm disappears → fault in motor/cable; if alarm persists → drive hardware failure
- Cross Swap Test (Same-axis model)
Swap motor + encoder cable to a healthy drive, judge whether fault source is motor or drive
- Motor Coil Test
Power OFF, measure U/V/W phase resistance with multimeter. Resistance difference between three phases <5%; conduction between any phase and PE = motor shorted to ground
❗ Do NOT use megger on encoder circuit, encoder chip will be destroyed
- Periodic Maintenance Checklist
- Ежемесячно: Tighten connectors, inspect cable wear; clean fan dust
- Ежеквартальный: Check motor bearing noise; retighten coupling and mechanical screws
- Annual: Inspect grounding and shielding integrity; record motor temperature rise; back up drive firmware
- Battery-free ABS model: Regularly verify home origin logic to avoid origin loss caused by external shaft rotation at power-off
- Примечания по безопасности
Main circuit capacitor retains high voltage after power-off, wait ≥5 minutes before disconnecting wiring
Do NOT perform insulation resistance test (megger) with drive connected
Do NOT touch rotating shaft while servo is ON to prevent mechanical injury
Parameter Setting Guide for OMRON 1S Servo R88M-1L1K030T-S2 + R88D-1SN10F-ECT (Сисмак Студия, NX/NJ Controller)
Мотор: 23-bit battery-free absolute encoder, нет тормоза; EtherCAT bus drive, STO safety terminals must be short-circuited, otherwise servo ON is unavailable.
Encoder resolution per revolution: 8388608 counts/rev
Препараты
- Hardware Wiring: Power cable U/V/W/PE, encoder cable, EtherCAT cable, short STO1/STO2, ESTP emergency stop wiring;
- Install Sysmac Studio on PC, connect NX/NJ controller via USB;
- Pre-power inspection: shaft can be rotated manually without jamming, AC230V power supply normal, reliable grounding;
- Create new project in controller, select corresponding NX/NJ CPU.
- Scan EtherCAT Bus and Identify Servo Drive
- [Configuration and Setup] → [EtherCAT], right-click EtherCAT Master → Compare and Merge with Actual Network
- Software automatically scans EtherCAT slaves and recognizes R88D-1SN10F-ECT drive;
- Confirm drive node address, щелкнуть [Apply], bus state becomes PREOP;
Stuck at INIT: faulty cable / wrong node address; PREOP is normal, bus enters OP after project download.
- Right-click drive → Assign Drive to Axis, motion axis (Axis0) generated automatically.
- Drive Quick Setup Wizard (Критический!)
Right-click R88D-1SN10F-ECT drive → Setup and Tuning → Quick Parameter Setup and I/O Monitor
- Мотор & Encoder Setting (Key for this model)
Модель двигателя: R88M-1L1K030T-S2, software auto-load matching parameters;
Тип кодера: Battery-free Absolute Encoder
Absolute Mode Option: Use Absolute Encoder, Ignore Multi-turn Overflow (Рекомендуется)
For first use, motor replacement, corrupted multi-turn encoder data: щелкнуть [Clear System], drive restarts to clear multi-turn data. Тревога 27.01 will pop up, this is normal.
- I/O Terminal Setting
СТО: Hardwired short;
ESTP external emergency stop: connect E-stop button; IN1 can be disabled in software if unused;
POT/NOT limit switches, DEC home sensor: включить по необходимости; disable in software if not wired.
- Motor Rotation Direction Test
Click [Servo ON], use JOG to test rotation direction;
Reverse rotation: tick [Reverse Motor Rotation Direction], download parameters to drive;
- Save parameters to drive EEPROM.
- Motion Axis Parameter Configuration (Unit Conversion / Electronic Gear)
Double-click generated motion axis Axis0 → [Axis Parameters]
Encoder count per revolution: 8388608 pulse/rev
Случай 1: Ball Screw (Screw lead 5mm, reduction ratio 1:1)
1 motor revolution → worktable moves 5mm
Command count per motor revolution: 8388608
Travel distance per motor revolution: 5 мм
Единица: мм
Значение: 8388608 encoder pulses of motor correspond to 5mm mechanical displacement. System calculates electronic gear automatically. For 1S bus servo, do NOT fill electronic gear manually, set mechanical travel directly.
Случай 2: Rotary Axis, motor directly connected to turntable, 1 rev = 360°
Travel distance per motor revolution: 360 deg
Единица: degree
Axis Limit Parameters
Максимальная скорость: motor rated speed 3000rpm, convert to corresponding mechanical speed;
Acceleration/Deceleration: set longer time (0.2~0.5s) at initial commissioning, shorten after tuning;
Soft Limit: давать возможность, set positive and negative soft limit values;
Home Setting (Battery-free ABS)
✅ Battery-free absolute encoder: current position can be read at normal power-up, no mandatory home return every power-on; if shaft is rotated by external force during power-off, origin is lost and 27.01 alarm triggered, home calibration required
Home Mode: [Absolute Origin Preset], set mechanical zero position as origin;
If external home sensor is used: select home search mode (reverse near / home input).
- Servo Gain Auto-tuning (Easy Tuning, Recommended for Beginners)
Right-click drive → Setup and Tuning → Easy Tuning
- Select tuning mode: Simple mode;
- Select mechanical type: Ball screw / Belt / Direct drive;
Ball screw: relatively high rigidity; Belt: low rigidity;
- Set JOG travel and speed;
- Click Start, drive runs reciprocally automatically, identifies load inertia and generates position loop gain, speed loop gain and filter automatically;
- Save gain parameters to drive EEPROM after tuning;
If simple tuning is insufficient, использовать [Advanced Auto-Tuning] or manually modify [Mechanical Rigidness 0~31]. Higher value = higher gain and faster response, excessive value causes vibration and squeal
Experience: Ball screw 8~16; Belt mechanism 3~8.
- Important Drive Parameter List
| Параметр Элемент | Описание & Reference Value for this Model |
| Код двигателя | R88M-1L1K030T-S2, auto-written by wizard, DO NOT modify manually |
| Encoder Mode | Battery-free ABS |
| Torque Limit | По умолчанию 300% (3脳 overload), can be reduced to prevent collision |
| Regenerative Resistor | Built-in regeneration for light load; external regenerative resistor required for frequent fast deceleration & large inertia load |
| Communication Cycle | Recommended EtherCAT bus cycle 500渭s / 250渭s, unified cycle for multi-axis synchronization |
| Vibration Suppression Filter | Enabled automatically after auto-tuning; notch filter can be manually enabled for mechanical resonance |
- Download Project and Commissioning Procedure
- Сохранить проект, download project to NX/NJ controller;
- Write drive parameters into EEPROM (prevent parameter loss after power-off);
- Monitor screen: check axis status, actual position, ток двигателя, bus OP state;
- Program use MC_Power to enable servo; MC_MoveAbsolute / MC_MoveRelative for positioning;
- JOG test run, проверять: rotation direction, abnormal vibration/noise, positioning performance;
- Home Calibration: move mechanism to mechanical zero position, execute [Set Current Position as Origin].
- Общие сигналы тревоги & Parameter-related Faults
- 27.01 Absolute Value Clear: Shaft rotated by external force while powered off, multi-turn encoder data lost; re-run Clear System and calibrate origin;
- 87.00 ESTP Emergency Stop Alarm: Emergency stop circuit open, check IN1 wiring or disable E-stop in software;
- STO-related Alarms: STO1/STO2 not short-circuited, safety circuit open, servo cannot enable;
- 21.00 Encoder Cable Breakage: Loose encoder cable, oxidized pins, poor shield grounding;
- Motor Shaking: Excessive gain, reduce mechanical rigidness and re-run auto-tuning;
- Poor Position Deviation: Incorrect unit conversion parameter, uncompensated backlash, slipping coupling.
- Важные примечания
- После изменения параметра, must save to drive EEPROM, parameters will not be retained after drive power-off otherwise;
- Battery-free ABS: position is retained if shaft remains stationary at power-off; origin lost if shaft is rotated externally during power-off;
- Reduce torque limit during commissioning to prevent mechanical collision damage;
- Bus servo, no manual calculation and entry of electronic gear ratio, набор [Travel Distance per Revolution] in axis parameters;
- Drive must be restarted after modifying motor model or encoder type for changes to take effect.
NH42-63-318x560.png "Автоматические переключатели резерва типа PC CHINT (АТС)НХ42-63/4СЗ")